Description
ADEPT 12000-310 Full English Technical Document
Product Title
ADEPT 12000-310 1.5kW Industrial Robot Servo Drive Unit for ADEPT SCARA and 6-Axis Robotic Systems
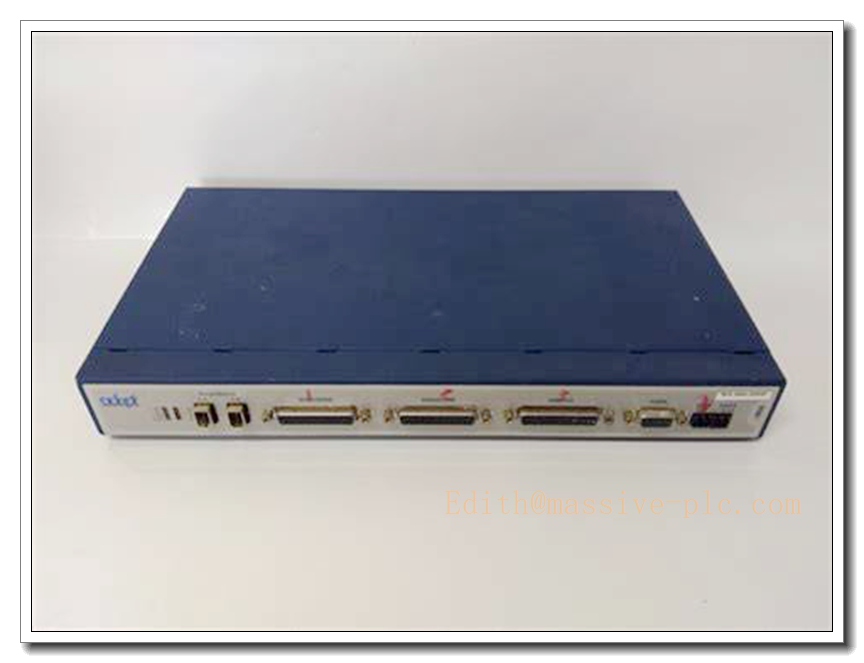
ADEPT 12000-310
Product Description
The ADEPT 12000-310 is a high-performance industrial robot dedicated servo drive module originally developed by ADEPT Technology (now part of the Omron Group). As the core power conversion hub for ADEPT robotic systems, it seamlessly pairs with ADEPT SCARA robots, 6-axis robotic arms, and the ADEPT Controller 100 platform. It converts AC power into precisely regulated kinetic energy for robot joints, delivering ±0.01mm motion control accuracy to support ultra-precise operations in 3C electronics assembly, automotive component manufacturing, and semiconductor wafer handling scenarios. It is a widely trusted drop-in replacement spare part for legacy ADEPT robot system retrofitting, restoring aged robot performance to near-new levels at 40% of the cost of full robot replacement.
Technical Specifications
- Manufacturer: ADEPT Technology (Omron Group)
- Part Number: 12000-310
- Product Type: Industrial Robot Servo Drive Unit
- Rated Output Power: 1.5 kW
- Control Architecture: Position-speed-torque triple closed-loop vector control
- Position Control Accuracy: ±0.01 mm
- Repeat Positioning Error: ≤0.005 mm
- Dynamic Response Time: ≤5 ms
- Maximum Supported Motor Speed: 3000 rpm
- Communication Interfaces: Native ADEPT robot system bus, supporting Ethernet, RS232, RS485 industrial protocols
- I/O Configuration: 16 digital input points, 16 digital output points
- Pulse Output Frequency Range: 0.5 MHz to 20 MHz
- Operating Temperature Range: -10°C to +60°C
- Physical Dimensions: 110 mm × 60 mm × 30 mm
- Net Weight: 0.2 kg
- Safety Protection Features: Built-in overload, overvoltage, overcurrent, and motor overheating protection
- Mean Time Between Failures (MTBF): ≥72000 hours
- Warranty Period: 12 months from factory delivery
Key Features and Advantages
- Native full compatibility with ADEPT SCARA and 6-axis robotic systems eliminates the need for third-party adapter hardware, enabling seamless plug-and-play integration with ADEPT robot motors and controllers without complex reconfiguration
- Advanced triple closed-loop vector control architecture delivers industry-leading ±0.01mm motion accuracy, ensuring zero deviation even for 0.1mm-pitch chip pin welding and micro-component assembly operations
- Ultra-fast 5ms dynamic response drastically shortens robot full action cycle to 0.8 seconds, boosting production line throughput by over 20% compared to generic servo drives
- Built-in multi-layer safety protection mechanism automatically triggers power cutoff and alarm under overload, overvoltage, overcurrent, or motor overheating conditions, preventing permanent hardware damage from operation errors or grid fluctuations
- Compact low-power consumption modular design supports hot-swap replacement, minimizing on-site maintenance downtime during robot system retrofitting
- Full backward compatibility with legacy ADEPT robot systems enables performance recovery of units over 5 years old to near-new levels, cutting equipment upgrade costs by over 60%
- Industrial-grade EMI/EMC interference resistance design guarantees long-term stable operation in harsh high-electromagnetic-interference workshop environments
- Integrated on-board status indicator LEDs provide real-time fault location feedback, drastically reducing troubleshooting time for maintenance personnel
Model Parameter Details
| Part Number | Core Configuration |
|---|---|
| 12000-310 | Standard 1.5kW robot servo drive, triple closed-loop vector control, ±0.01mm positioning accuracy, 5ms dynamic response, full ADEPT SCARA/6-axis robot system compatibility |
Application Fields
- 3C electronics industry high-precision micro-component assembly and chip welding
- Automotive electronics production line sensor and precision component handling
- Semiconductor manufacturing process wafer and fragile component low-damage transportation
- Automated packaging and sorting production line high-speed robotic material handling
- Legacy ADEPT industrial robot system drive module failure replacement and performance retrofitting
- New energy lithium battery production line electrode and module precision assembly scenarios
Related Product Recommendations
- ADEPT Controller 100 Robot Main Control Unit
- ADEPT 12000-310 Dedicated Servo Motor Feedback Encoder Cable Kit
- ADEPT High-Precision Absolute Encoder Servo Motor Set
- ADEPT Robot System Official Configuration and Diagnostics Software
- ADEPT 12000 Series Servo Drive Module DIN Rail Mounting Bracket Kit
- ADEPT Robot System Redundant AC Power Supply Unit
- ADEPT Robot Motion Control Expansion I/O Module
- ADEPT 12000-310 Field Calibration and Debugging Toolkit
Pre-Installation Safety Precaution
Before initiating any hardware installation or wiring procedures, ensure all connected ADEPT robot systems and high-power servo circuits are fully de-energized, locked out, and tagged in strict compliance with local industrial electrical safety regulations. Only qualified industrial robot maintenance personnel with professional high-voltage operation certification are authorized to perform installation work. Never insert or remove the module while the system is powered on, as improper hot-plug operations may cause permanent hardware damage or unexpected robot movement safety risks.
Hardware Installation Steps
- Select a dedicated mounting position on the DIN rail inside the robot control cabinet, ensuring sufficient ventilation clearance around the module, avoiding direct exposure to high-temperature radiation, moisture, or corrosive industrial dust
- Secure the module firmly to the DIN rail, confirming the mechanical locking mechanism engages completely to prevent vibration-induced disconnection during long-term robot operation
- Connect the AC power wiring to the module’s dedicated power terminals, verifying the power supply voltage matches the module’s rated specification before applying power
- Terminate all servo motor encoder feedback and robot system bus wiring strictly following the official ADEPT wiring schematic, confirming signal polarity, shielding single-point grounding, and terminal labeling accuracy
- Wire all digital I/O signal cabling to the robot controller and peripheral safety interlock devices, ensuring all safety loop connections are fully consistent with the original system design requirements
- Torque all wiring terminals to the specified torque values, and install dedicated cable strain relief for all external field wiring runs
System Configuration Workflow
- Power on the module after completing all wiring checks, confirm the power indicator LED on the front panel illuminates in normal steady state with no active fault alarms
- Connect the configuration engineering workstation to the ADEPT robot controller service port, launch the official ADEPT robot system configuration software to establish stable communication with the new drive module
- Complete basic device parameter setup, including module identification, connected servo motor parameter matching, and encoder type configuration
- Calibrate all motion control loop parameters, including position loop gain, speed loop gain, and torque limit values, to match the specific mechanical load characteristics of the on-site robot
- Configure robot system bus communication parameters, enabling seamless real-time data exchange between the new drive and the robot main control unit
- Customize motion protection interlock logic and fault alarm thresholds according to specific on-site production process requirements, then save the full configuration profile to the robot system non-volatile memory
Post-Installation Verification Checklist
- Confirm all front-panel status LEDs operate in normal state, with no persistent active fault or warning indicators
- Validate that real-time robot joint position, speed, and torque feedback values fully match the expected operational parameters
- Perform no-load robot motion testing, confirming the module delivers smooth, stable motion control response without abnormal vibration or hunting
- Test the built-in self-diagnostic protection functions manually, confirming the module correctly identifies overload, overvoltage, and signal disconnection anomalies and triggers corresponding fault alarms
- Verify end-to-end communication connectivity between the module and the ADEPT robot main control unit, confirming complete, uncorrupted real-time motion data transmission
- Trigger the full system power cycle test, confirming the module resumes normal operation automatically after power restoration without configuration loss or false alarm events